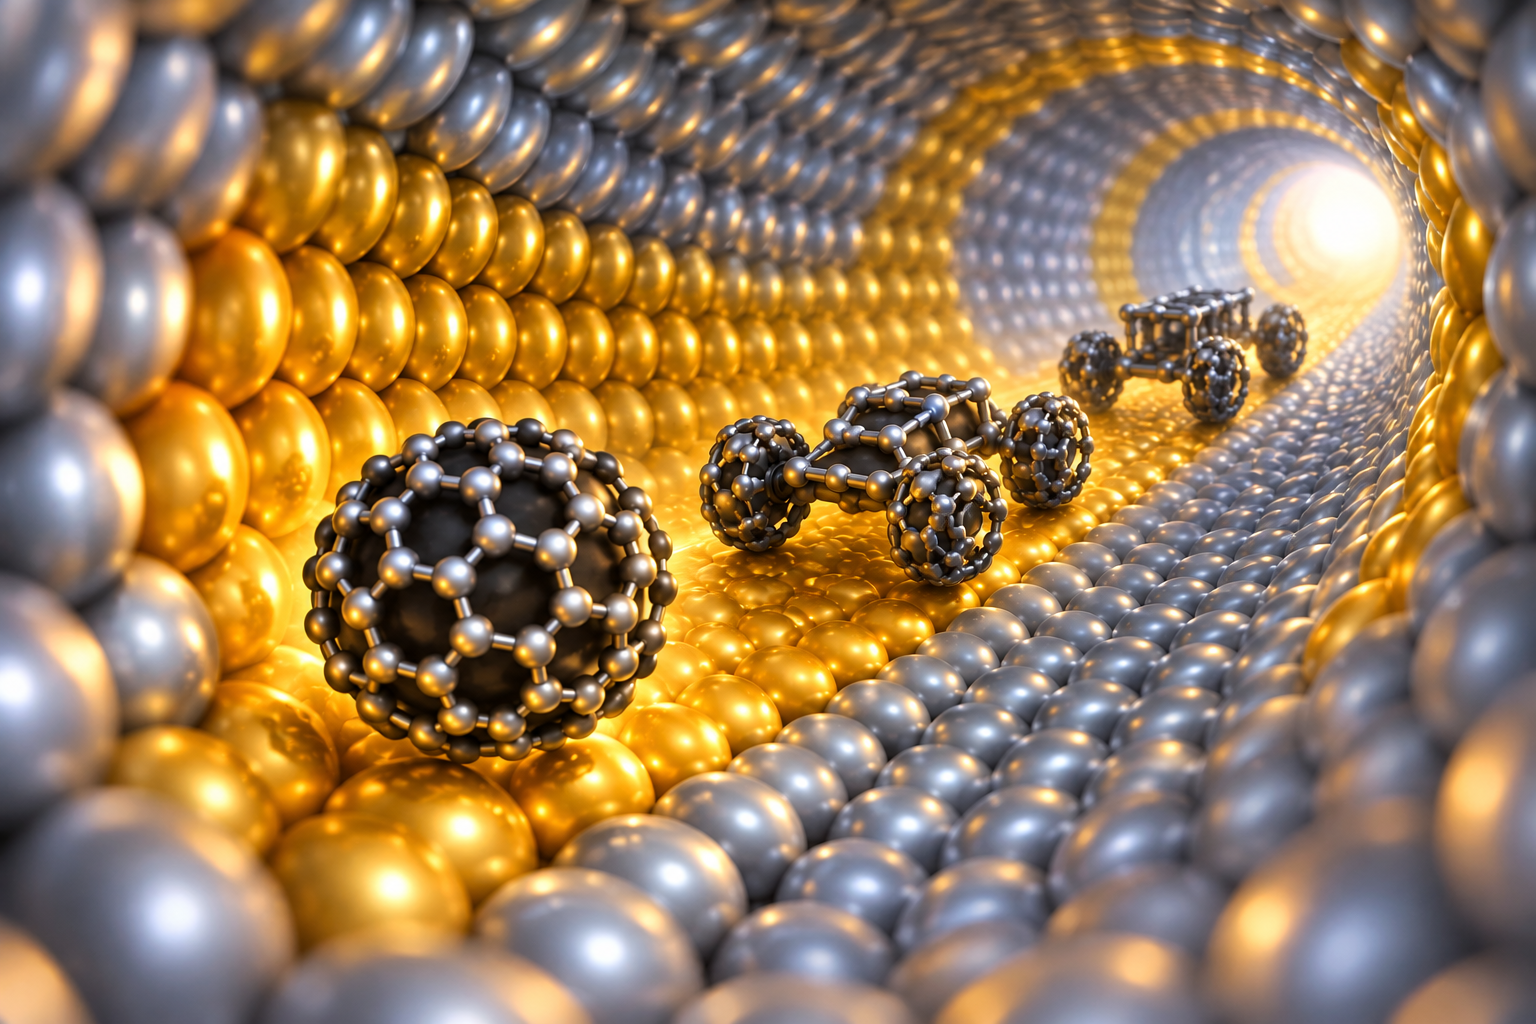
Simulations reveal how subtle changes in metallic track geometry interact with molecular flexibility, producing strikingly different trajectories for fullerene-based nanomachines.
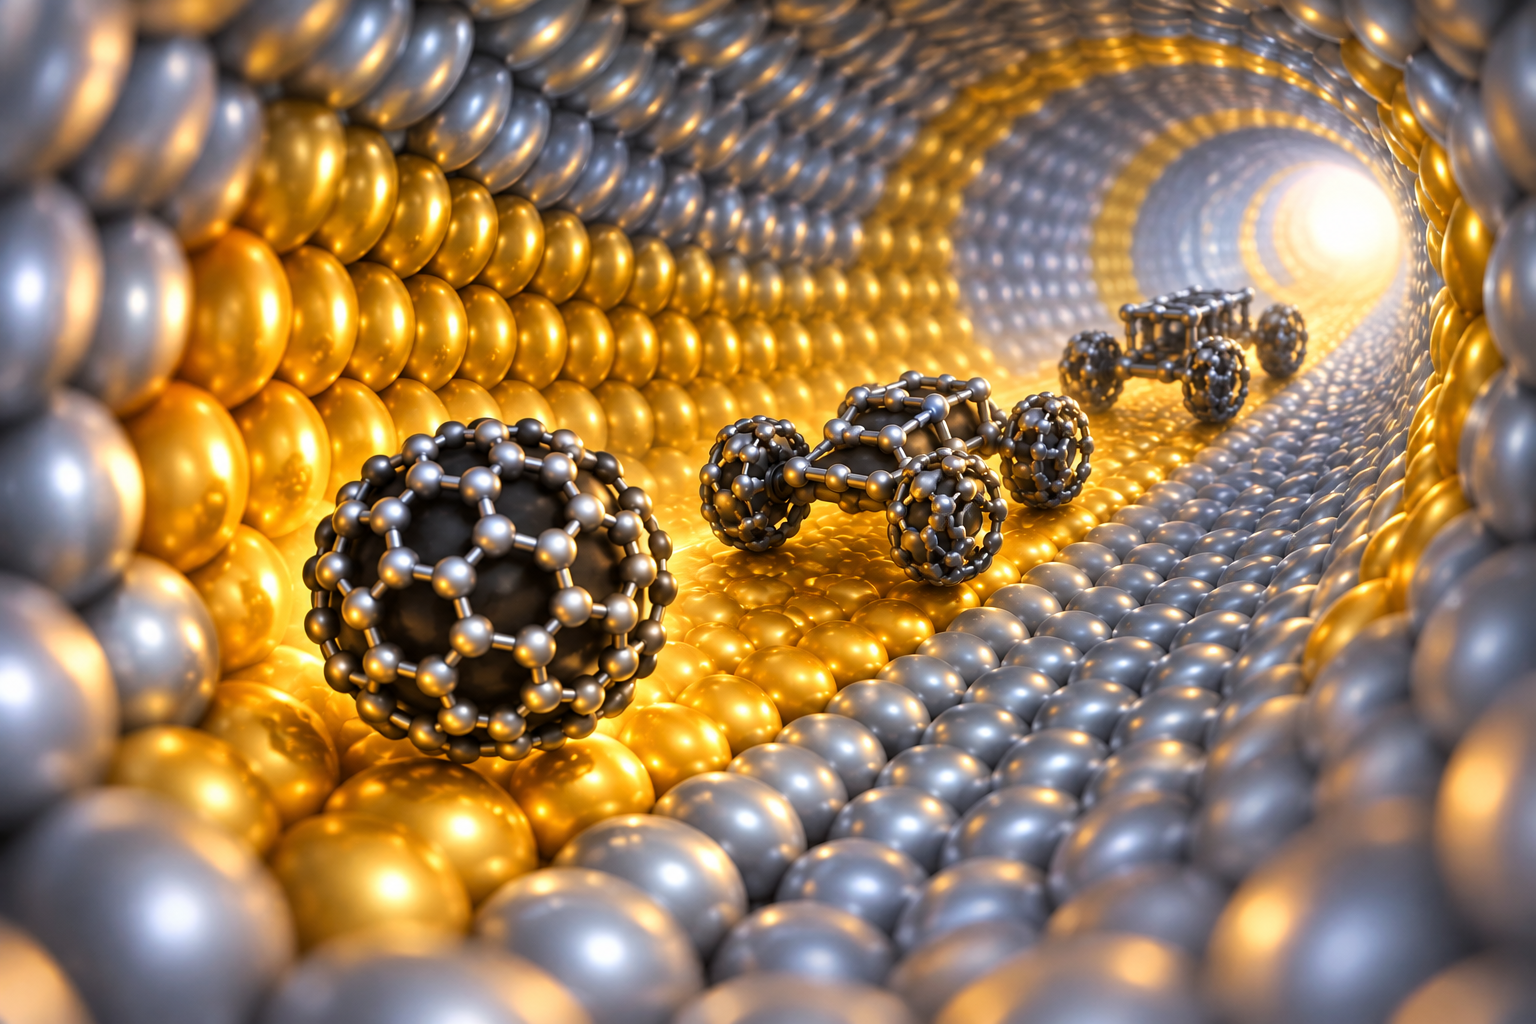
Paper: Controlling the diffusion of fullerene-wheeled nanovehicles using hybrid curved substrates. AI-generated abstract conceptual image created using ChatGPT/OpenAI
In a recent research article published as an ‘Article in Press’ in the journal Scientific Reports, researchers investigated the control of the diffusive motion of fullerene-wheeled nanovehicles, including C60, nanocars, and nanotrucks, using all-atom molecular dynamics simulations on hybrid curved substrates featuring a gold impurity line on a silver cylindrical surface.
Guiding Nanovehicle Diffusive Movement
The world of nanotechnology is constantly pushing boundaries, offering the promise of molecular transport, bottom-up assembly, and intricate mechanical tasks at an atomic scale. A persistent challenge in this field is converting the inherently diffusive, often random, motion of nanomachines into precisely guided trajectories.
This simulation study examines a possible approach: hybrid curved substrates embedded with gold impurity lines. By strategically integrating a gold track into silver cylindrical surfaces, the simulations indicated that differences in nanovehicle interactions with gold and silver could guide the erratic journey of nanovehicles, such as fullerene-wheeled nanocars and nanotrucks, along a preferred path across temperatures from 75 K to 600 K.
The findings provide a computational design strategy for future studies of molecular transport and manipulation at the nanoscale.
Hybrid Substrate Simulation Setup
Researchers used an all-atom molecular dynamics approach to examine the proposed guidance mechanism. The core of their simulation setup involved a silver cylindrical substrate, carefully designed with a floating inner layer for the nanomachines to traverse and a rigid outer base for stability.
A distinct line of gold impurity was introduced onto this silver surface. The width of this gold line was a critical variable, engineered to span 120°, 150°, or 180° of the complete cylinder’s circumference. Three specific nanovehicles were chosen for the study: the spherical C60 fullerene, a flexible-chassis nanocar approximately 3 nm x 4 nm in size, and a rigid-chassis nanotruck measuring around 2 nm x 3 nm.
The optimal cylindrical radii for these nanomachines, previously determined to be 30 Å for C60, 25 Å for the nanocar, and 17.5 Å for the nanotruck, were adopted from earlier work for the simulations.
The simulations were conducted across a wide temperature range, from 75 K to 600 K, allowing the researchers to examine thermal effects on their motion. The authors noted that previous work indicates metallic nanotubes retain their wall structure at temperatures well above the simulated range.
Potential energy analysis was a key method for characterizing the motion of these nanovehicles. The authors also drew on previous work showing that the “Hexa-down” orientation of C60 on gold has the lowest potential energy among the configurations examined.
The researchers calculated diffusion coefficients from mean-square displacement to compare nanovehicle mobility across the different geometries and temperatures. This computational setup enabled examination of the complex interplay between nanovehicle structure, substrate geometry, and thermal energy, supporting the proposed method for controlling molecular-machine paths at higher temperatures.
Chassis Flexibility Dictates Motion
This study investigated the control of nanovehicle diffusion on hybrid silver-gold cylindrical substrates, revealing that optimal guidance depends on both substrate design and molecular architecture.
For C60 fullerene, the 150° gold line was the best overall configuration across the simulated temperature range, serving as a preferred adsorption track while the surrounding silver regions helped restrict lateral motion. This configuration yielded the highest diffusion coefficients at every temperature except 75 K and the greatest net displacement at most temperatures, while maintaining relatively low directional deviations. At 600 K, C60 could enter the surrounding silver region, showing that confinement was not absolute.
The flexible-chassis nanocar performed best for high-temperature directional guidance on the wider 180° substrate, particularly at elevated temperatures (400–600 K). Its flexibility required more lateral space to accommodate conformational changes without scattering from the silver boundaries, leading to more linear and efficient motion. Narrower paths (120°, 150°) were associated with increased deviations at higher temperatures. Across most temperatures, the 150° track still produced the highest displacement and generally the highest diffusion coefficient. The nanocar also showed a higher average diffusion coefficient than the nanotruck, which the authors attributed to its chassis flexibility.
The rigid-chassis nanotruck achieved optimal long-range, directed movement on the narrow 120° substrate. Its structural rigidity benefited from strong confinement, limiting deviations. The 150° path produced erratic trajectories, whereas the 180° path provided weaker guidance, though favorable displacement was observed at 500 and 600 K. The nanotruck exhibited angular velocities approximately one order of magnitude lower than the nanocar, supporting its greater resistance to directional changes due to its rigid chassis.
The simulations suggested that rigid nanomachines benefit from narrow confinement, while flexible ones require broader paths for effective guidance.
Tailoring Nanovehicle Path Control
This research identified preferred track widths for guiding C60 fullerene, nanocars, and nanotrucks on hybrid cylindrical substrates, demonstrating a possible computational method for guiding molecular machines.
The results indicate that nanovehicle motion depends not only on wheel structure but also on chassis rigidity; flexible nanocars favor wider tracks, while rigid vehicles benefit from stronger confinement.
This study suggests that combining different metallic surfaces, such as gold and silver, could create defined trajectories and improve control over molecular motion, providing a basis for future experimental testing.